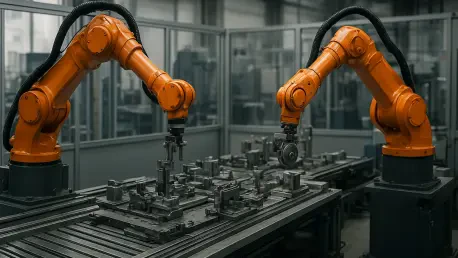
The sudden transition from proprietary silos to open-source foundational software is currently fundamentally restructuring the global industrial robotics landscape through the release of the Intrinsic Core platform. This pivot by Alphabet’s robotics arm represents a calculated effort to lower the barriers to entry for millions of small and medium-sized manufacturers who have long been priced out of the automation market. By offering a sophisticated suite of ROS-compatible tools for free, the company aims to move the industry away from specialized, high-cost engineering toward a more democratized model of flexible automation. This analysis explores the economic and technological repercussions of this shift, examining whether these open building blocks can truly catalyze a new era of distributed manufacturing and physical intelligence.
Understanding the Historical Barriers to Automation Adoption
Historically, the adoption of robotics has been a privilege of the industrial elite, restricted by a rigid model that prioritized mass production over adaptability. Industry data from recent years indicate that most companies struggled with the “integration tax,” which refers to the hidden costs of making a robot perform a specific task beyond its initial purchase price. The requirement for custom physical fixtures, specialized programmable logic controller (PLC) programming, and extensive safety infrastructure often tripled the price of the robot arm itself. These background factors matter because they created a stagnation in the market, where only the automotive and semiconductor industries could justify the long-term return on investment.
Furthermore, a significant lack of internal automation experience acted as a secondary gatekeeper. For decades, deploying a robot was never a “plug-and-play” affair; it required a team of highly specialized engineers to script every minute movement with surgical precision. This meant that the vast majority of the world’s manufacturers—the “long tail” of small shops—remained stuck with manual processes despite the rising costs of labor and global competition. The release of open-source foundational tools serves as a direct challenge to this legacy, attempting to solve the flexibility problem through adaptable software rather than expensive, static hardware.
Architecture and Innovation: The Pillars of Intrinsic Core
The technical foundation of this new platform is built upon a modular architecture that treats robotic capabilities as interchangeable building blocks. By providing these components through an open-source license, the industry is moving toward a standard where the software layer acts as a universal translator between different hardware brands and sensors.
Achieving Hardware Agility: Real-Time Control
The control framework serves as a hardware-agnostic layer that addresses the persistent problem of vendor lock-in. Previously, switching between different robot brands or grippers necessitated a total rewrite of the underlying driver code, creating a significant sunken cost for any facility. By decoupling the control software from specific mechanical hardware, the platform allows for a more modular approach to factory design. This agility is further enhanced by digital twin integration, which allows engineers to validate complex physical movements in virtual environments before a single motor turns on the factory floor. This high-fidelity simulation reduces the risk of hardware damage and significantly accelerates the deployment timeline for new automation cells.
Reducing Physical Costs: Advanced Perception
One of the most significant financial burdens in traditional automation has always been the physical fixturing required to keep parts perfectly aligned for the robot. However, the integration of advanced six-degrees-of-freedom part tracking shifts this burden from expensive hardware to digital intelligence. When a robot can use sensors to detect, identify, and handle parts in various orientations, the need for custom-engineered steel fixtures vanishes. This shift from physical hardware to digital perception drastically lowers the financial threshold for entering the automation space. It enables manufacturers to automate low-volume, high-mix production lines where the cost of traditional fixtures would otherwise be prohibitive.
Autonomous Motion: From Manual Programming to Planning
Moving beyond the era of joint-by-joint manual instruction, the industry is now pivoting toward autonomous motion and grasp planning. Traditional programming methods were notoriously fragile, as even the slightest change in the physical environment could break a pre-programmed sequence. The new approach utilizes what is increasingly called “Physical AI” to generate collision-free paths dynamically. This capability allows robots to function effectively in semi-structured environments, closing the technical skill gap by automating the complex mathematics required for spatial reasoning. By removing the need for a technician to script every movement, the platform addresses the labor shortage that has long hindered the scaling of robotic fleets in smaller enterprises.
Future Landscapes: Global Manufacturing and Physical AI
Looking ahead from 2026 to 2028, the trajectory of industrial installations suggests a shift toward more ready-made, open-source reference designs. While global robot installations reached record highs in the mid-2020s, the market’s next phase of growth depends on its ability to penetrate sectors beyond traditional heavy industry. Ready-made solutions, such as open machine tending designs, are becoming the new standard for small machine shops looking to automate repetitive tasks like CNC loading. As these open-source tools continue to mature, we can expect a shift where industrial-grade support and advanced AI become accessible commodities. This evolution will likely lead to a more resilient and distributed global supply chain that is less dependent on localized labor clusters and more reliant on flexible, intelligent systems.
Strategic Implementation: Best Practices for Modern Manufacturers
For businesses aiming to navigate this transition, the focus must shift from purchasing static hardware to investing in software flexibility and interoperability. The major takeaway from the current market shift is that proprietary, closed ecosystems are becoming a strategic liability rather than an asset. Modern manufacturers should prioritize ROS-compatible hardware and utilize advanced simulation tools to de-risk their investments. Starting with high-volume, low-complexity tasks—such as simple part transfer or machine tending—provides a manageable entry point before scaling toward more complex, AI-driven applications. By adopting a modular strategy, companies can ensure that their automation investments remain adaptable to changing market demands and technological advancements.
A New Paradigm: Reflections on Industrial Progress
The emergence of Intrinsic Core effectively signaled a departure from the exclusive, high-cost models that defined the previous era of industrial development. This shift was significant because it forced a total reassessment of how value was generated on the factory floor, moving the focus from hardware ownership to software capability. By providing the essential building blocks for free, the initiative successfully lowered the economic threshold for sophisticated automation, allowing a broader range of manufacturers to experiment with advanced perception and motion planning. Strategic investments in vendor-neutral software frameworks ensured that companies remained resilient against supply chain disruptions and hardware shortages. The transition to an open paradigm eventually proved to be the decisive factor in whether industrial robotics could reach its full potential as a universal tool for global productivity, paving the way for a more decentralized and agile manufacturing economy.